

-
Tel : +86 20 8278 0427
-
Correo electrónico : info@stsystemplc.com
Tel : +86 20 8278 0427
Correo electrónico : info@stsystemplc.com
Recommended direction: divide the route into engineering zones, detect legitimate users before they enter each zone, raise a continuous corridor of light ahead of travel, and retain approved scenes locally when the external network is unavailable. Use radar-video fusion only at high-value entrances, junctions and service gates; ordinary track segments can use simpler detection where the risk and evidence justify it.
The control strategy should begin with the operating envelope, not a preferred device. Define pedestrians, bicycles, motorcycles and authorized four-wheel service vehicles; set the permitted and design speed separately; then calculate detection distance, response time, illuminated look-ahead and hold time. A configurable sensor range of 1–100 km/h is a capability range, not permission for vehicles to travel at 100 km/h.
| Decision | Recommended Basis | Evidence Required Before Award | Acceptance Outcome |
|---|---|---|---|
| Control unit | Route zone, normally several coordinated poles rather than an isolated luminaire. | Zone drawing, pole addresses, scene list and failure boundaries. | Correct poles respond together from both travel directions. |
| Detection method | Match radar, video or fused sensing to geometry, user mix and consequence of a missed event. | Coverage plot, target list, speed band and environmental limits. | Required users detected; nuisance and missed-event rates recorded. |
| Lighting response | Background-to-active transition with enough look-ahead for the approved design speed. | Timing budget, dimming curve, optical design and maintained-light calculation. | Measured response and continuous corridor meet the agreed values. |
| Communication | PLC, LoRA or hybrid by power topology, radio survey and recovery requirement. | Topology, channel-loss behavior and local-storage boundaries. | Commands, alarms and fallback work under injected failures. |
| Operational proof | FAT for logic; SAT for real route behavior. | Approved scripts, instruments, raw records and signed exceptions. | Repeatable evidence supports handover and maintenance. |
A long track should not be treated as one uniform control problem. A straight low-use segment, a blind downhill bend, a crowded entrance and a maintenance gate have different detection distances, lighting scenes and evidence needs. Route segmentation turns those differences into controlled design inputs and prevents one aggressive setting from being copied along the entire corridor.
Start with chainage, track width, gradients, horizontal and vertical curves, obstructions, pole positions, feeder boundaries, access points, weather exposure and expected user density. Then assign a zone type and document the design assumption. The matrix below is a starting framework; final values belong in the project-specific lighting calculation and SAT method.
| Route Zone | Primary Risk | Detection / Control Direction | Lighting Scene | Minimum Site Evidence |
|---|---|---|---|---|
| Straight, low-use segment | Late recognition of a lone slow user; excessive energy use during empty periods. | Bidirectional detection with conservative slow-user coverage and a coordinated look-ahead zone. | Approved background level; smooth rise to active level; timed recovery after the final valid event. | Walk and ride tests in both directions, energy baseline, response time and hold-time record. |
| Blind bend or crest | User enters an unreadable area before the next sensor or pole responds. | Place detection before the decision point; overlap coverage and extend the illuminated corridor beyond the obstruction. | Earlier activation and, where justified, a higher or longer active scene without abrupt glare. | Approach photographs, coverage plot, illuminance/uniformity results and ride-through video. |
| Steep descent | Higher approach speed shortens the available response time. | Use the approved design speed, measured system latency and safety margin to calculate upstream detection distance. | Stable active scene through the descent; avoid repeated zone drop-outs during continuous travel. | Timed trials at the highest permitted test speed and verification of the complete response budget. |
| Entrance, junction or crossing | Conflicting movements, unauthorized access or incomplete situational awareness. | Consider radar-video fusion, status indicators and operator-visible events; define privacy and retention boundaries. | Conflict or priority scene may override energy-saving scenes under approved rules. | Multi-target scenarios, operator display, event record, manual override and recovery test. |
| Race / dense group zone | Continuous riders can cause scene oscillation or gaps between detections. | Refresh occupancy while valid events continue; allow a scheduled event mode with clear authority. | Stable event lighting for the defined period; background strategy resumes only after controlled release. | Dense-group simulation, schedule test, manual command record and post-event restoration. |
| Service gate / maintenance area | Authorized vehicles need wider coverage; work crews may remain stationary. | Detect vehicle approach and provide authorized maintenance control; separate track policy from sensor capability. | Maintenance scene with longer hold time and defined return to automatic operation. | Vehicle trials, stationary-work scenario, access record and timeout verification. |
| Fog, snow, coastal mist or sand exposure | Reduced contrast, glare and unreliable environmental assumptions. | Use validated weather input and operator authority; avoid claiming that CCT alone guarantees penetration. | Evaluate approximately 2700K warm-light and normal white-light scenes with actual optics and conditions. | Comparative visibility, glare, CCT, power and transition records under representative conditions. |
The matrix separates verified inputs from proposed settings. Pole spacing and detection range must be reconciled on the route drawing; a nominal sensor range should never be copied directly into the tender as an achieved safe look-ahead distance.
The bicycle track lighting and safety management system links motion detection with neighboring lighting zones. When an approved target enters a sensing area, the current segment and selected segments ahead rise to their agreed lighting scene. The occupied scene remains active while detections continue; brightness returns gradually to the approved standby scene after the hold period expires.
The system should be judged by safe scenes, local fallback, alarm traceability and owner-held records. A useful evidence chain includes CH-800 Gateway zones, FAT/SAT files, offline tests, communication-route records, alarm logs, maintenance closure and configuration backups. AI-assisted analysis becomes useful when these field records are dependable.
| Operating Step | Lighting Behavior | Evidence to Review |
|---|---|---|
| Detect | Sensor reports movement within the configured field of view. | Target direction, coverage, mounting height and nuisance sources are checked on the track. |
| Prepare ahead | Gateway or local group logic raises the selected segments ahead. | Neighbor map, response time and uninterrupted visibility are demonstrated in both directions. |
| Maintain | Further detections renew the occupied scene and hold timer. | Continuous groups do not cause premature dimming or repeated brightness oscillation. |
| Return smoothly | The zone returns to its approved background scene after the clear period. | Standby illumination and transition rate match the approved lighting design. |
| Record | Events, commands, energy and faults are retained according to the project scope. | The owner can inspect source identity, timestamps and configuration version. |
A straight-road sensor layout cannot simply be repeated along every bend. Curves, crests, cuttings, trees and retaining walls may hide approaching riders from a sensor mounted farther down the track. Place detection and lighting zones around the real sightline, with overlap where a person may disappear briefly behind terrain.
On downhill sections, the illumination sequence should follow the approved rider-speed envelope and the available sight distance. On uphill sections, a slow cyclist or pedestrian must not fall below a speed threshold that was chosen only for vehicles. At sharp bends, maintain a stable background scene and test the approach from both directions.
| Track Condition | Practical Issue | STSYSTEMPLC Design Approach |
|---|---|---|
| Blind bend | Detection may occur too late if a sensor sees only the exit. | Add upstream sensing and overlap; illuminate the visible approach and curve before entry. |
| Crest or gradient | Terrain can interrupt line of sight; speeds differ uphill and downhill. | Use separate approach zones and test both slow uphill targets and faster downhill riders. |
| Dense cycling group | Repeated motion can keep a route occupied for long periods. | Refresh the hold timer; use continuous scenes during sustained occupancy. |
| Track crossing | Pedestrians and cyclists can enter from a side path. | Include cross-path sensing and a junction scene, rather than only longitudinal detection. |
| Resting or repair area | A person may stop moving while still needing light. | Use a persistent safe scene or suitable presence logic; do not rely only on motion pulses. |
| Emergency access point | Motorcycles or four-wheel vehicles may join the track. | Provide manual priority and service scenes with an approved access policy. |
The detection scope includes pedestrians, bicycles, motorcycles and four-wheel motor vehicles. For this track context, support and inspection vehicles are expected to travel within about 30–50 km/h, with bends, gradients and cyclists limiting practical vehicle speed. These operating assumptions should be confirmed by the owner before commissioning.
A sensor that detects movement does not necessarily identify vehicle type, recognize a rider, or provide a certified speed measurement. The lighting scene can respond to the approved detection input without collecting personal identity. If the project needs object classification, exact speed reporting or individual race tracking, those functions require separately specified hardware and acceptance tests.
| Target Group | Representative Field Test | Acceptance Requirement |
|---|---|---|
| Pedestrian | Slow walking, approach from different angles, brief stops. | Verify low-speed detection and ensure the standby scene remains usable when motion stops. |
| Single cyclist | Different riding speeds, clothing and bicycle profiles. | Confirm early triggering and continuous lighting across zone boundaries. |
| Group of cyclists | Closely spaced riders and sustained occupancy. | Test hold-timer renewal and simultaneous detections across several zones. |
| Motorcycle | Narrower profile and different approach geometry. | Include an actual motorcycle test; do not infer performance only from car detection. |
| Four-wheel support vehicle | Inspection, maintenance and event-support access. | Test approved 30–50 km/h operation where track rules allow, together with manual service scenes. |
The selected STSYSTEMPLC sensor configuration can support a configurable 1–100 km/h speed band. This is a configuration range for sensing behavior, not a recommendation to allow 100 km/h traffic on a cycling route. Final settings depend on the sensor model, installation angle, target direction and validated field performance.
The lower boundary matters as much as the upper boundary. Raising it to reduce nuisance events could exclude slow pedestrians or cyclists climbing a slope. Configure the speed band together with field of view, sensitivity, persistence and lighting-zone rules; check the result with actual users before acceptance.
Verify pedestrians, starts, stops and slow bicycles near the lower end of the approved band. Protect genuine slow movement when nuisance filtering is tuned.
Use observed and planned operating speeds to calculate detection distance and the number of poles required ahead of travel.
Test the owner-approved service-vehicle range, commonly around 30–50 km/h in this project context. Keep permission rules separate from device capability.
Wind-driven vegetation, small animals, moving shadows, rain and adjacent traffic can produce nuisance events depending on sensor technology and installation. STSYSTEMPLC sensing settings should be configured to reduce unwanted triggers while preserving detection of legitimate track users. No sensor should be accepted solely from a claim that all interference is removed.
Begin by narrowing the sensing area to the track, avoiding nearby trees where practical and separating adjacent road traffic from cycling-zone logic. Then tune the selected sensor settings and compare occupied and unoccupied test periods. Record both missed detections and unwanted triggers so the owner can see the trade-off.
| Nuisance Source | What to Examine | How to Verify |
|---|---|---|
| Vegetation in wind | Sensor field includes moving branches or grass. | Adjust aiming and coverage; compare windy unoccupied periods with pedestrian and cyclist passes. |
| Small animals | An animal crosses near the sensing area. | Review available filtering and target settings; confirm slow human detection remains reliable. |
| Rain, dust or fog | Environmental conditions differ from dry commissioning. | Test relevant weather conditions and use a documented fallback scene for uncertain sensing. |
| Adjacent road vehicles | A nearby road shares the sensor field. | Separate coverage and zone mapping; verify that remote traffic does not brighten the whole track. |
| Simultaneous users | Several legitimate targets occupy overlapping zones. | Maintain the occupied scene and prevent one clear sensor from overriding another active zone. |
The objective is a readable corridor ahead of the user, with smooth transitions between occupied and background scenes. Advance lighting distance should be selected from route geometry, speed, pole spacing, detection range and total system response. A sensor range is not automatically the same as the distance over which neighboring luminaires can be commanded.
For initial planning, selected sensing arrangements may be evaluated around 50–100 m approaches where the chosen sensor and mounting geometry support that coverage. This remains a design assumption until measured on site. A long illuminated zone can be prepared by group control even when the initiating sensor sees a much shorter local area.
A valid event raises the coordinated route segment before the user reaches it.
New valid events extend occupancy and prevent dark gaps during groups or continuous flow.
After the final event and hold time, the scene returns smoothly to the approved background level.
An ordinary evening, a crowded training session and an organized race do not need identical dimming behavior. The operator should be able to select an approved scene with a clear scope, start time, end time and restoration rule. Event control should be available through authorized local operation as well as the agreed platform.
During a race, steady lighting through occupied competition segments may take priority over occupancy savings. During quieter periods, local detection can raise selected zones while the rest remain at the approved background level. Maintenance scenes should identify the working area and preserve visibility for approaching riders.
| Scene | Lighting Policy | Trigger or Authority | Acceptance Focus |
|---|---|---|---|
| Daily operation | Background lighting with occupied-zone uplift. | Sensor events, renewed hold time and gradual return. | Verify minimum scene and route continuity. |
| Dense training | Extended occupied scene over active zones. | Repeated detections keep the scene active. | Avoid premature dimming between groups. |
| Organized race | Stable event illumination through the approved route. | Authorized event schedule or local override. | Record selected zones, approval and return to normal. |
| Inspection or repair | Local working scene and approaching-route visibility. | Maintenance authorization and work-order reference. | Record operator, affected assets and closure. |
| Weather scene | Approved brightness and CCT for the weather condition. | Weather input or authorized manual selection. | Measure visibility, glare and scene recovery. |
| Communication interruption | Stored local schedule and approved sensing behavior. | External-network failure policy. | Demonstrate continuity and later record synchronization. |
Key entrances, exits and junctions can be equipped with an integrated radar-video unit to strengthen visual safety management and refine zone dimming. Radar supplies supported movement information, while video gives operators a view of the scene. Together, they can help the owner understand how cyclists, pedestrians and authorized service vehicles share critical access points.
Deploy these units at priority locations and combine them with distributed track sensors. Through the selected device’s supported event or metadata interface, a project integration can link validated occupancy, direction or speed information to CH-800 Gateway zone rules. The lighting response can prepare the approach, hold busy junctions at the approved scene and return gradually to the agreed background level.
Use live video and available radar information to review approaching users, conflicts and event conditions at entrances and crossings.
Adapt the affected zone’s approved brightness, advance-lighting group and hold time to validated activity information and operator authority.
Link source events, scene commands and available video references so the owner can review what happened and how the lighting responded.
Radar-video integrated monitoring reference: at key entrances, exits and junctions, the selected radar-video unit can combine supported movement information with live visual review. Through the specified interface, validated events can support CH-800 Gateway zone control, advance lighting, occupied-scene hold time and operator review.
| Priority Location / Situation | Visual Management Value | Dimming and Scene Linkage | Site Acceptance Check |
|---|---|---|---|
| Main entrances and exits | Combine radar target information with live video for a clearer view of movement through the access point. | Raise the entry, crossing and connected approach zones to the approved occupied scene before users enter. | Test both travel directions with pedestrians, bicycles, motorcycles and four-wheel service vehicles. |
| Crossings and converging routes | Help operators review interacting movements and dense activity at junctions. | Keep the junction and selected neighboring segments raised while occupancy continues. | Verify detection overlap, simultaneous targets, hold-time renewal and a stable junction scene. |
| Dense cycling groups | Use supported occupancy or traffic-flow information to help operators understand sustained use. | Select a stable group-use scene rather than repeatedly dimming between closely spaced riders. | Validate the selected device’s counting or occupancy capability; compare field activity with recorded events. |
| Authorized service vehicles | Use supported direction and speed metadata with video to review vehicle access. | Apply an approved service-access scene to the affected zones, with controlled restoration afterward. | Confirm target capability, event fields and authorized scene priority for the installed configuration. |
| Abnormal movement or incident review | Link available analytics events with visual confirmation by the operator. | Allow an authorized operator to raise the affected area or invoke an approved priority scene. | Specify supported event types; test alarm source, video reference, operator action and closure. |
| Quiet periods and sensor faults | Provide a live view when available and distinguish valid low occupancy from lost detection. | Return gradually to the approved background level after the clear period; retain an approved fallback scene on sensor or link failure. | Test lost metadata, video interruption, external-network loss and restoration without unsafe dimming. |
The selected radar-video model, analytics and interface determine the available target information and event functions. Specify and test the integration before delivery. Brightness limits remain within the approved photometric scenes, and local lighting continues according to the agreed fallback rules if video or analytics becomes unavailable.
The system connects sensing inputs, individual light controllers, cabinet or supply zones, CH-800 Gateway / Centralized Controller logic and the selected management platform. The owner receives a route map that relates a physical pole to its controller, circuit, gateway and operating scene.
Cloud access can support remote management where permitted. On-premises servers, Ethernet or fiber can support an owner-controlled management environment. The local field-control layer should retain the approved behavior when external connectivity is interrupted; loss of remote visibility should be distinguishable from loss of illumination.
| System Layer | Operating Role | Owner-Held Evidence |
|---|---|---|
| Sensor layer | Report approved movement or environmental inputs. | Coverage plan, mounting detail, settings and detection test record. |
| Optional radar-video unit | Provide supported target events / metadata and visual review at key access points through the specified integration. | Model and interface scope, time alignment, zone-event mapping, video-access roles and fallback test. |
| Status and broadcast layer | Provide approved four-color indications, recorded / live voice announcements, LED information and video guidance at selected locations. | Status dictionary, message and content library, priority map, zone linkage, operator roles and interruption behavior. |
| Lamp controller | Execute dimming, CCT scenes and selected local fallback. | Device identity, command feedback, scene limits and firmware reference. |
| Cabinet / supply zone | Organize power responsibility and local operating inputs. | Circuit map, isolation procedure, supply status and manual authority. |
| CH-800 Gateway | Coordinate route zones, stored rules and field records. | Zone map, configuration backup, event history and offline behavior. |
| Communication route | Carry field commands and status through the selected channels. | Coverage measurements, path records and measured recovery behavior. |
| Platform and owner files | Review alarms, energy, maintenance and configuration. | Account roles, exports, retention policy and handover package. |
Communication should be selected from the actual power layout and terrain. PLC can use suitable existing power conductors, while LoRA can provide a wireless route where the electrical network does not offer a reliable common communication path. A dual-channel design can provide an alternative route when one channel is degraded.
For selected STSYSTEMPLC hybrid configurations, 0.1 s channel takeover is a project performance target to demonstrate in the specified test conditions. Record direction of transfer, load, interference condition and end-to-end lighting behavior. A working communication backup also needs powered field devices; a backup data path does not restore power to an unpowered luminaire.
| Review Item | PLC | LoRA | HYBRID PLC & LoRA |
|---|---|---|---|
| Existing lighting conductors | Useful where feeder topology and noise permit reliable PLC. | Independent of a common conductor communication path. | Use each channel according to measured site quality. |
| Mixed or irregular supplies | Different transformers and feeder boundaries can complicate communication. | Useful where pole power originates from different circuits. | Survey feeder boundaries and provide wireless coverage where required. |
| Terrain and wireless shadowing | Does not depend on direct wireless visibility, but depends on conductors. | Coverage may need gateway placement or additional route planning. | Validate bends, cuttings and gateway overlap on both channels. |
| Cable interruption or strong electrical noise | Affected conductor route may become unavailable. | Alternative data path can continue where devices remain powered. | Demonstrate PLC-to-LoRA transfer under the agreed fault condition. |
| Wireless interference or lost coverage | A healthy conductor route can remain available. | Affected wireless route may become unavailable. | Demonstrate LoRA-to-PLC transfer under the agreed condition. |
| Single-route dependency | One principal field path. | One principal field path. | Alternative field paths with documented priority and recovery logic. |
| Commissioning scope | Measure conductor quality, feeder limits and device density. | Measure RF coverage, noise, terrain effects and local regulatory settings. | Test both routes separately, then fault transfer and recovery together. |
External network failure should not make an occupied track wait for a cloud command. Store the approved scene and schedule behavior in the selected local controllers and CH-800 Gateway configuration. Define how sensing, manual override and abnormal-condition scenes operate during an interruption.
The exact fallback depends on which part fails. Loss of the internet, loss of the gateway, loss of one field channel and loss of luminaire power are different events. Test them separately and record the visible lighting behavior, retained events and return-to-normal sequence.
Local schedules and approved scenes continue where configured; alarms and history synchronize after recovery.
The affected boundary follows its local fallback; unaffected zones continue independently where the topology allows.
Use the agreed safe scene, log the fault and restore the approved configuration from an owner-held backup.
Consulting-grade content distinguishes demonstrated project facts from product capability, design intent and assumptions that still require site verification. This prevents a reference video from being misread as proof that every bicycle-specific function has already been delivered. It also lets procurement compare suppliers on the same evidentiary basis.
| Evidence Grade | Meaning | Acceptable Support | How It Should Be Written |
|---|---|---|---|
| A — Project verified | The stated function and scope are supported by identifiable project records. | Signed acceptance, approved drawing, test record, delivery list or owner-confirmed reference. | State the project, delivered scope, date or version, and the specific verified result. |
| B — Product verified | A selected product capability is supported by current technical documentation or controlled test. | Datasheet, certificate, laboratory report, protocol document or witnessed FAT. | State the model, configuration and limits; do not imply route performance without a site design. |
| C — Design proposal | A technically reasoned solution is proposed for this route but is not yet site-accepted. | Calculation, coverage plot, control narrative, interface schedule and risk review. | Use “proposed”, “designed to” or “subject to SAT”; identify the open acceptance item. |
| D — Assumption / validation required | An input or outcome is uncertain and materially affects the design. | Assumption register with owner, due date and validation method. | Do not present it as achieved performance; show the consequence if the assumption changes. |
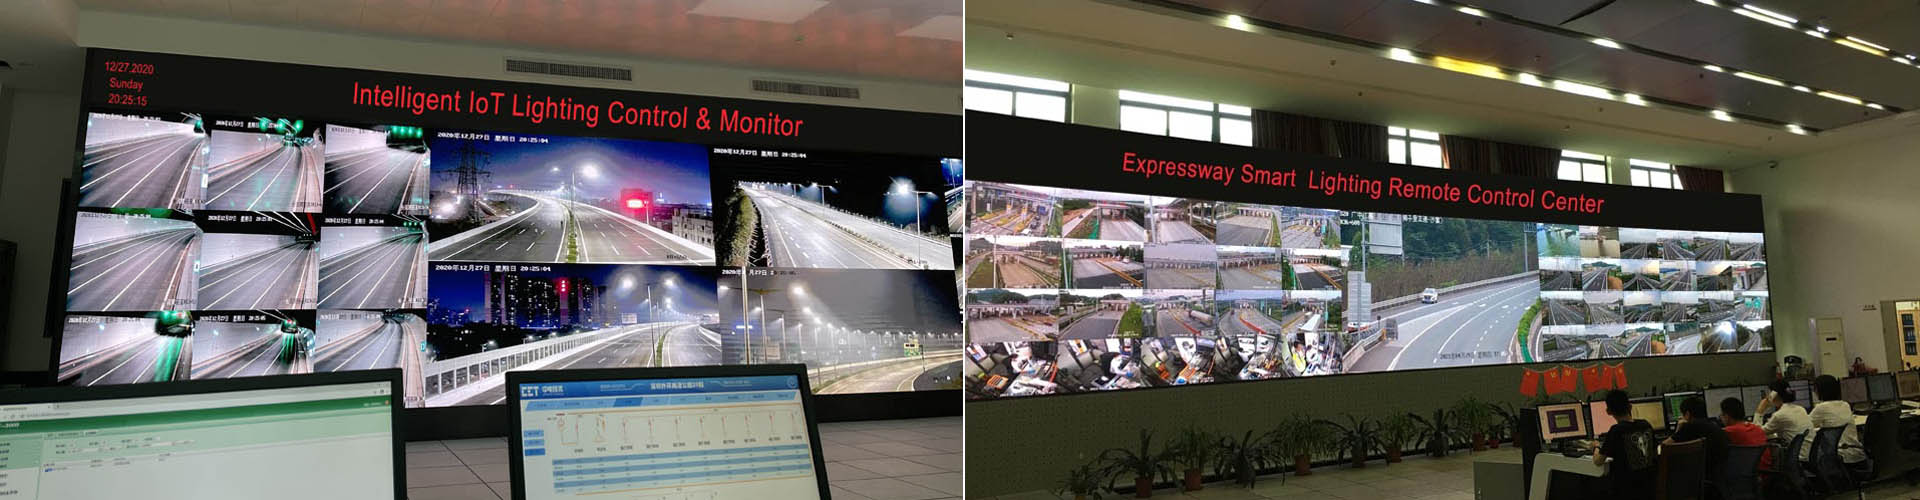
BANYIN Freeway project reference: this video provides evidence of sensor-related, coordinated field-lighting experience. For a bicycle lane or cycle track, transfer the engineering method—not an unqualified performance claim. Bicycle, pedestrian, motorcycle and service-vehicle detection, route-specific scenes and response timing must be demonstrated in the project FAT/SAT scope.
Apply the same rule to all claims: a configurable 1–100 km/h sensing band is not a statement that the track permits 100 km/h; an AI-assisted review function is not personal rider tracking; a hybrid communication option is not proof of uninterrupted service; and a maximum luminaire efficacy is not a maintained route-lighting result. Each statement should lead to a document, calculation or test.
Factory Acceptance Testing should prove configuration and integration before delivery. Site Acceptance Testing should prove the real route with its bends, slopes, vegetation, electrical supplies and permitted traffic. Both stages should produce records the owner can inspect and retain.
Agree test routes and pass criteria before installation. Include the slowest approved user, both directions, side entrances, continuous groups and service vehicles. Repeat representative tests with normal scenes, event scenes and the agreed interruption cases. A short straight-line demonstration is insufficient for a varied cycling corridor.
| Acceptance Item | FAT Before Delivery | SAT on the Track | Owner-Held File |
|---|---|---|---|
| Asset identity | Map sensor, pole, controller, cabinet and gateway identifiers. | Check random physical assets against route and platform records. | Asset list, route map and zone table. |
| Target coverage | Define supported targets and sensing settings. | Test pedestrians, bicycles, motorcycles and four-wheel vehicles. | Target-pass records and installed settings. |
| Bend and gradient | Prepare zone overlap and advance-lighting rules. | Traverse both directions at approved speeds and difficult approaches. | Route test, scene sequence and response timing. |
| Dense groups | Verify repeated-trigger and hold-timer logic. | Test sustained groups and simultaneous zone occupancy. | Detection history and no-premature-dimming result. |
| Radar-video linkage, where supplied | Confirm supported targets, analytics events, metadata interface and lighting-zone mapping. | Test entrance / junction activity, video and event alignment, scene commands, dimming limits and lost-input fallback. | Integration scope, event / command log, visual reference and recovery record. |
| Indicators and broadcast | Approve color meanings, messages, visual content, event priorities and zone mappings. | Test each indicator, recorded / live voice path, display content, lighting linkage, manual override and communication interruption. | Status matrix, message library, content approval, audibility / readability checks and event record. |
| Nuisance filtering | Prepare sensitivity, coverage and available filter settings. | Compare occupied and unoccupied periods with relevant nuisance sources. | Missed / unwanted trigger records and adjustments. |
| Photometric scenes | Validate luminaire configuration and approved scene limits. | Measure relevant light levels, uniformity and glare evaluation. | Photometric files and site measurement report. |
| PLC / LoRA routes | Verify both channels and fault-transfer logic where supplied. | Interrupt each channel and measure behavior under agreed conditions. | Route quality, transfer timing and recovery record. |
| Outside-network loss | Load local schedules, scenes and fallback rules. | Disconnect the external link and observe field operation. | Offline result, retained logs and restoration record. |
| Weather / dual CCT | Check selected 2700K ↔ 6000K rules and manual override. | Verify trigger, scene, recovery and measured output. | CCT scene file and weather-input test. |
| Power reserve | Agree backed-up scope and consumption assumptions. | Test selected outage and charging / reserve behavior. | Power test and reserve calculation. |
| Alarm closure | Prepare alarm dictionary and work-order fields. | Simulate a fault through dispatch, repair and closure. | Alarm log and maintenance closure report. |
| Owner handover | Prepare accounts, exports, backups and spare-part plan. | Confirm owner access and a practical restore demonstration. | Handover index, configuration backup and restoration result. |
Share the route length, bends and gradients, pole spacing, electricity access, rider density, race or event schedule, permitted service vehicles, weather exposure and owner acceptance rules. STSYSTEMPLC can develop a zone-based lighting-control and FAT/SAT proposal for the track.
Discuss the Track ProjectDownload Technical PDFs
Habla a : F4,Bldg A, Hanzhong Industrial Park, No.67, North of Xinsha Ave, Xin Tang, Zeng Cheng, Guang Zhou, China
Tel : +86 20 8278 0427
Correo electrónico : info@stsystemplc.com
Correo electrónico : morrison426@163.com